预告 | SLAI Seminar第四十七期
2026年8月6日(周四)下午4:30,深圳河套学院荣幸地邀请到穆罕默德・本・扎耶德人工智能大学(Mohamed bin Zayed University of Artificial Intelligence, MBZUAI)机器人方向的宋超阳副教授,在B401教室带来主题为“柔性触觉驱动的视觉形变感知”的学术报告分享。诚挚欢迎学院师生及对该领域感兴趣的产学研界同仁参与讲座。
Title
柔性触觉驱动的视觉形变感知
Vision-based Deformable Perception via a Soft Touch
About the Speaker
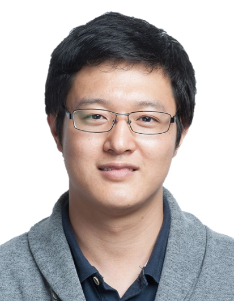
宋超阳 副教授
Assoc.Prof. Chaoyang Song
宋超阳现任穆罕默德・本・扎耶德人工智能大学机器人方向副教授。2018至2025年间,他担任南方科技大学(SUSTech)机械与能源工程系助理教授,同时兼任计算机科学与工程系助理教授。他的研究方向为设计科学与机器人学习交叉学科,聚焦跨肢体、跨场景、跨技能的融合研究。此前,他曾任莫纳什大学讲师、麻省理工学院(MIT)博士后、新加坡科技设计大学(SUTD)博士后。他持有南洋理工大学机构与机器人学博士学位,是IEEE高级会员。他累计发表80余篇论文,发表于高影响力期刊(例如《Science Robotics》、IJRR、T-RO、TMech、《Soft Robotics》、RA-L、《Advanced Intelligent Systems》)与学术会议(例如RSS、CoRL、ICRA、IROS、CASE)。他还斩获2023年联合国教科文组织国际高等教育创新中心高等教育数字化先锋案例奖,以及2023年CASE会议医疗自动化最佳论文奖。
Song Chaoyang is an Associate Professor of Robotics at Mohamed bin Zayed University of Artificial Intelligence. Between 2018 and 2025, he was an Assistant Professor at the Southern University of Science and Technology (SUSTech) in Shenzhen, affiliated with the Department of Mechanical and Energy Engineering and had an adjunct affiliation with the Department of Computer Science and Engineering. His research focuses on the interdisciplinary field of design science and robot learning that bridges across limbs, scenarios, and skills. Previously, he was a Lecturer at Monash University, a Post-Doc at Massachusetts Institute of Technology (MIT), and a Post-Doc at Singapore University of Technology and Design (SUTD). He holds a Ph.D. in Mechanism and Robotics from Nanyang Technological University. He is a Senior Member of IEEE. He authored over 80 papers published in high-impact journals (e.g., Science Robotics, IJRR, T-RO, TMech, Soft Robotics, RA-L, Advanced Intelligent Systems) and conferences (e.g. RSS, CoRL, ICRA, IROS, CASE). He also won the UNESCO-ICHEI Higher Education Digitalization Pioneer Case Award in 2023 and the Best Healthcare Automation Paper Award at CASE2023.
Abstract
物理具身是实现人类意图与机器智能对齐的核心,接触产生触觉的瞬间,便是仿真世界与现实世界建立真实关联的关键。本次报告将阐明:基于视觉的形变感知(VBDeformP)在搭建面向具身智能的机器人学习系统中具备基础性作用。依托视觉实现触觉感知,能够以较低成本,让现代机器人系统可共享、可复现地获取丰富模态的实时感官表征;这类表征采用多维、便于计算的数据结构。结合课题组近期在机器人本体感知学习方向的研究成果,宋教授将介绍一套技术方案:融合软体机器人设计与现代学习算法,实现具备全向适应性的触觉感知,性能达到当前最优水平(SOTA)。该方案经过一百万次测试循环后,依旧拥有极高鲁棒性。基于这一原理,本次报告将阐述如何借助各类学习算法、利用计算智能,从单一视觉输入中得到多模态输出。凭借这一独特能力,能够将具备全向适应性的触觉感知应用至跨肢体、跨技能、跨场景任务,例如水陆两栖触觉抓取、本体感知与内感知形体重建、工业焊接以及目标检测。随后,将介绍拓扑学习框架的初步研究成果:该框架通过图神经网络拓展触觉表征,能够同步训练操作与移动两类技能。最后,将介绍asMagiClaw系统。该系统可依靠单一设备采集包含力与运动信息的人类示教动作,致力于打造面向具身智能的通用交互接口,探索依托柔性触觉实现机器智能极致对齐的可行路径。
Physical embodiment is central in aligning human intentions with machine intelligence, where the moment of touch holds the truth between the simulated and real worlds. In this talk, Assoc. Prof. Song will argue for the foundational role of Vision-Based Deformable Perception (VBDeformP) in developing robot learning systems toward embodied intelligence. Tactile perception by vision provides modern robotic systems with shareable and reproducible access to a rich modality of real-time sensory representations in a multi-dimensional, computationally compatible data structure at a low cost. Drawing from their recent work in proprioceptive robot learning, Assoc. Prof. Song will explain their recipe that combines soft robotic design with modern learning algorithms to achieve State-of-the-Art (SOTA) performances in tactile perception with omni-directional adaptation. Their solution is highly robust even after 1 million test cycles. Based on this principle, Assoc. Prof. Song will present how they achieve multi-modal outputs from a single, vision-based input by leveraging computational intelligence via various learning algorithms. Such unique capability enables us to incorporate tactile sensing with omni-directional adaptation in cross-limb, cross-skill, and cross-scenario applications, such as amphibious tactile grasping, proprioceptive and interoceptive shape reconstruction, industrial welding, and object detection. Then, he will present their preliminary results in developing a topological learning framework that simultaneously trains manipulation and locomotion skills by expanding tactile representation via a Graph Neural Network. Finally, he will present asMagiClaw system that captures human demonstration actions, including both force and motion, within a single device towards a universal interaction interface for embodied intelligence, the path towards super-aligned machine intelligence via a soft touch.
Host
任洪亮 教授
Prof. Hongliang Ren
Date & Time
2026年8月6日(星期四)
下午4:30-6:00
August 6, 2026, Thursday,
4:30pm-6:00pm
Venue
深圳河套学院B401教室
(深圳市福田区福保街道红棉路6号,地图导航“深圳河套学院-南门”)
Room B401, Shenzhen Loop Area Institute
(6 Hongmian Rd, Fubao Sub-Street, Futian District, Shenzhen, navigate to "Shenzhen Loop Area Institute (South Gate)" on the map.)
Online link
扫码加入会议
Join the Meeting Online
腾讯会议号:948-1135-4043
Tencent Meeting:948-1135-4043