SLAI Seminar NO. 55 : Embodied Intelligence Reinforcement Learning Training and Intelligent Infrastructure Exploration
Title
Embodied Intelligence Reinforcement Learning Training and Intelligent Infrastructure Exploration
About the Speaker
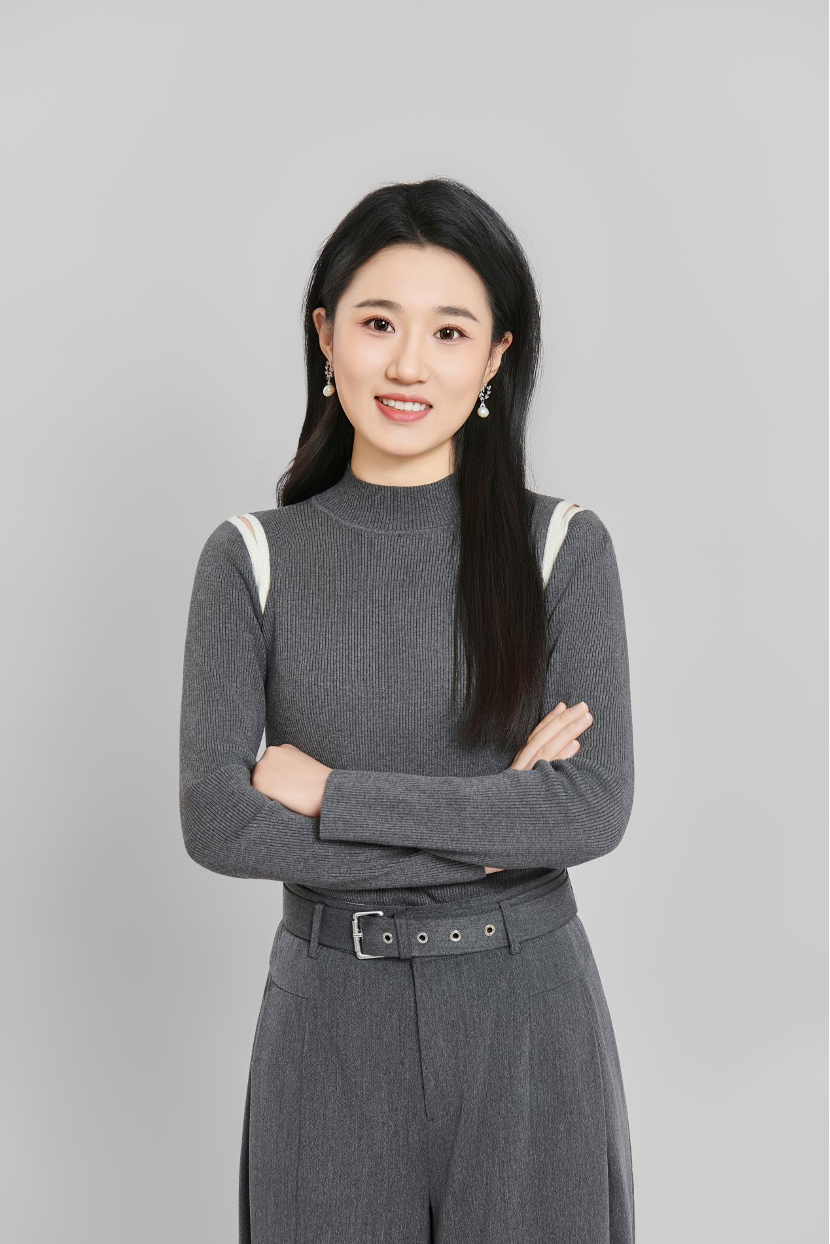
Asst. Prof. Chao Yu
Chao Yu is an Assistant Professor (Special Research Fellow) at the Shenzhen International Graduate School of Tsinghua University. She has been selected for the Young Promoters Program of the China Electronics Society. She has been engaged in research in the fields of reinforcement learning and robotics for many years. She has published more than 60 papers as the first author or corresponding author, with over 7,800 citations on Google Scholar. In the field of multi-agent reinforcement learning, her MAPPO algorithm, published as the first author (NeurIPS 2022), has been cited over 4,000 times on Google Scholar and has been incorporated into courses at top domestic and international universities. As a corresponding author, she presented research on a large-model reinforcement learning training algorithm at ICML 2024 (Oral, top 1.5%). Her work has been presented alongside that of top academic institutions such as OpenAI and Anthropic. She has recently developed the first large-scale reinforcement learning framework for embodied intelligence, RLinf, which has been open-sourced on GitHub and has received 5,000 stars and 700 forks. It has been officially included by NVIDIA’s Isaac Lab as the first embodied large-model training engine and has been adopted by several top companies and research institutions.
Abstract
Embodied intelligence is transitioning from a phase where it relies on the capabilities of large-scale pre-trained models to one where it enables intelligent agents that can continuously learn, autonomously execute, and evolve in the real world. However, the open environments, long-tail tasks, and complex interaction processes in the physical world pose new challenges to existing robot learning paradigms: on one hand, reinforcement learning provides an important pathway for robots to acquire experience through environmental interactions and enhance their generalization capabilities, but it still faces issues such as high costs in real-world robot training, low data efficiency, and difficulties in scaling deployment. On the other hand, while current vision-language-action (VLA) models possess strong semantic understanding and task execution capabilities, their ability to generalize tasks in open environments, plan over long periods, and adapt flexibly remains limited. New embodied frameworks are needed to further unleash their potential.
This report will focus on "Embodied Intelligence Reinforcement Learning Training and Intelligent Infrastructure Exploration." First, it introduces large-scale reinforcement learning training infrastructure for embodied foundational models. Through collaborative simulation and real-world training, heterogeneous resource scheduling, and online learning by real robots, it explores methods for continuous optimization and large-scale evolution of robot strategies. Subsequently, it presents intelligent infrastructure for VLA (Vision-Language-Action) models. By introducing task planning, memory management, skill abstraction, and composable execution mechanisms, VLA is transformed from a single end-to-end strategy into an intelligently schedulable, combinable, and continuously enhanced execution module. Finally, it looks ahead to the future direction of moving from "training stronger models" to "building continuously evolving agents," exploring a new paradigm where reinforcement learning training infrastructure and intelligent architecture jointly drive the development of embodied intelligence.
Host
Prof. Xiangfeng Wang
Date & Time
September 23, 2026, Wednesday,
2:30pm-4:00pm
Venue
Room B401, Shenzhen Loop Area Institute
(6 Hongmian Rd, Fubao Sub-Street, Futian District, Shenzhen, navigate to "Shenzhen Loop Area Institute (South Gate)" on the map.)
Online link
Join the Meeting Online
Tencent Meeting: 948-1135-4043